Overview
Q1. Consider the following robot:
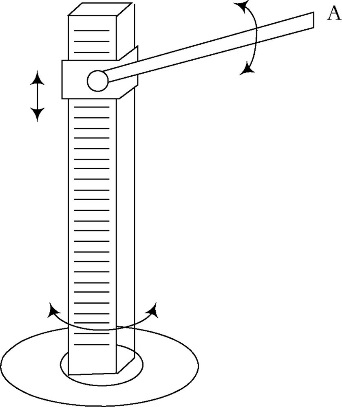
- How many links and joints does it have? Explain.
- Which coordinate type does it have? Explain.
- What is it DOF? Explain.
- Name and draw its workspace. Explain.
- Which application this robot is most suitable for? Explain why.
-------------------------------------------------------------------------------------------------------------------------------------------------------------------------This is my answer I don't know if it's correct
- How many links and joints does it have? Explain. 3 links and 3 joints
- Which coordinate type does it have? Explain. Spherical (P2R)
- Name and draw its workspace. Explain. Spherical